Libra 2000Series
Outdoor stereo depth cameras
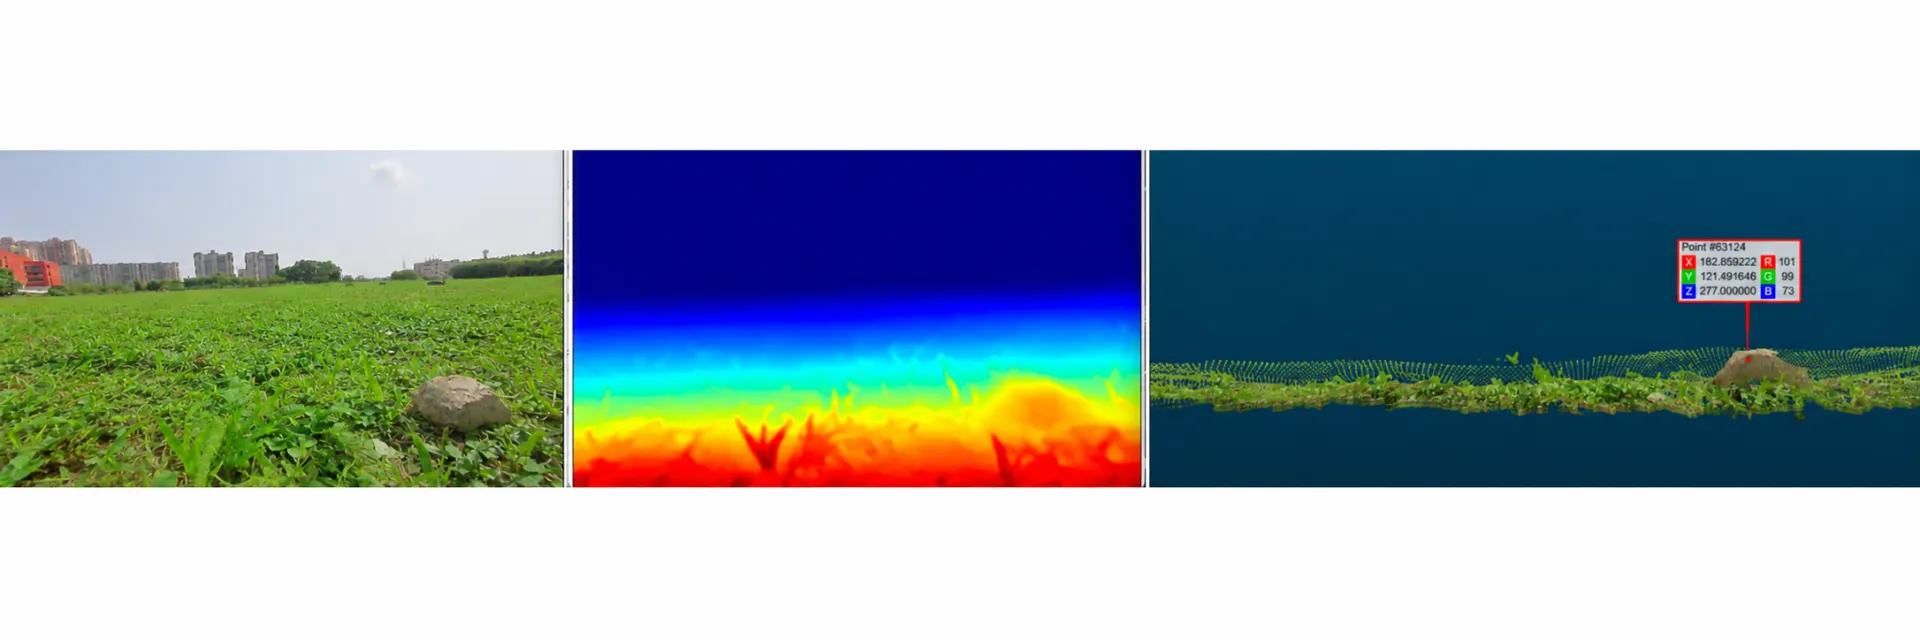
Designed for outdoor robotic mowers, the Libra 2000 series uses passive stereo 3D reconstruction. An onboard stereo depth model produces dense RGBD data within 2 m for real-time obstacle avoidance. Left and right stereo images are also available for obstacle avoidance, localization and mapping with stereo VSLAM.
Global-shutter stereo with onboard depth
Dual 1.3 MP global-shutter color cameras reduce motion distortion. Onboard stereo depth processing delivers dense RGBD data within 2 m in real time for robot obstacle avoidance.
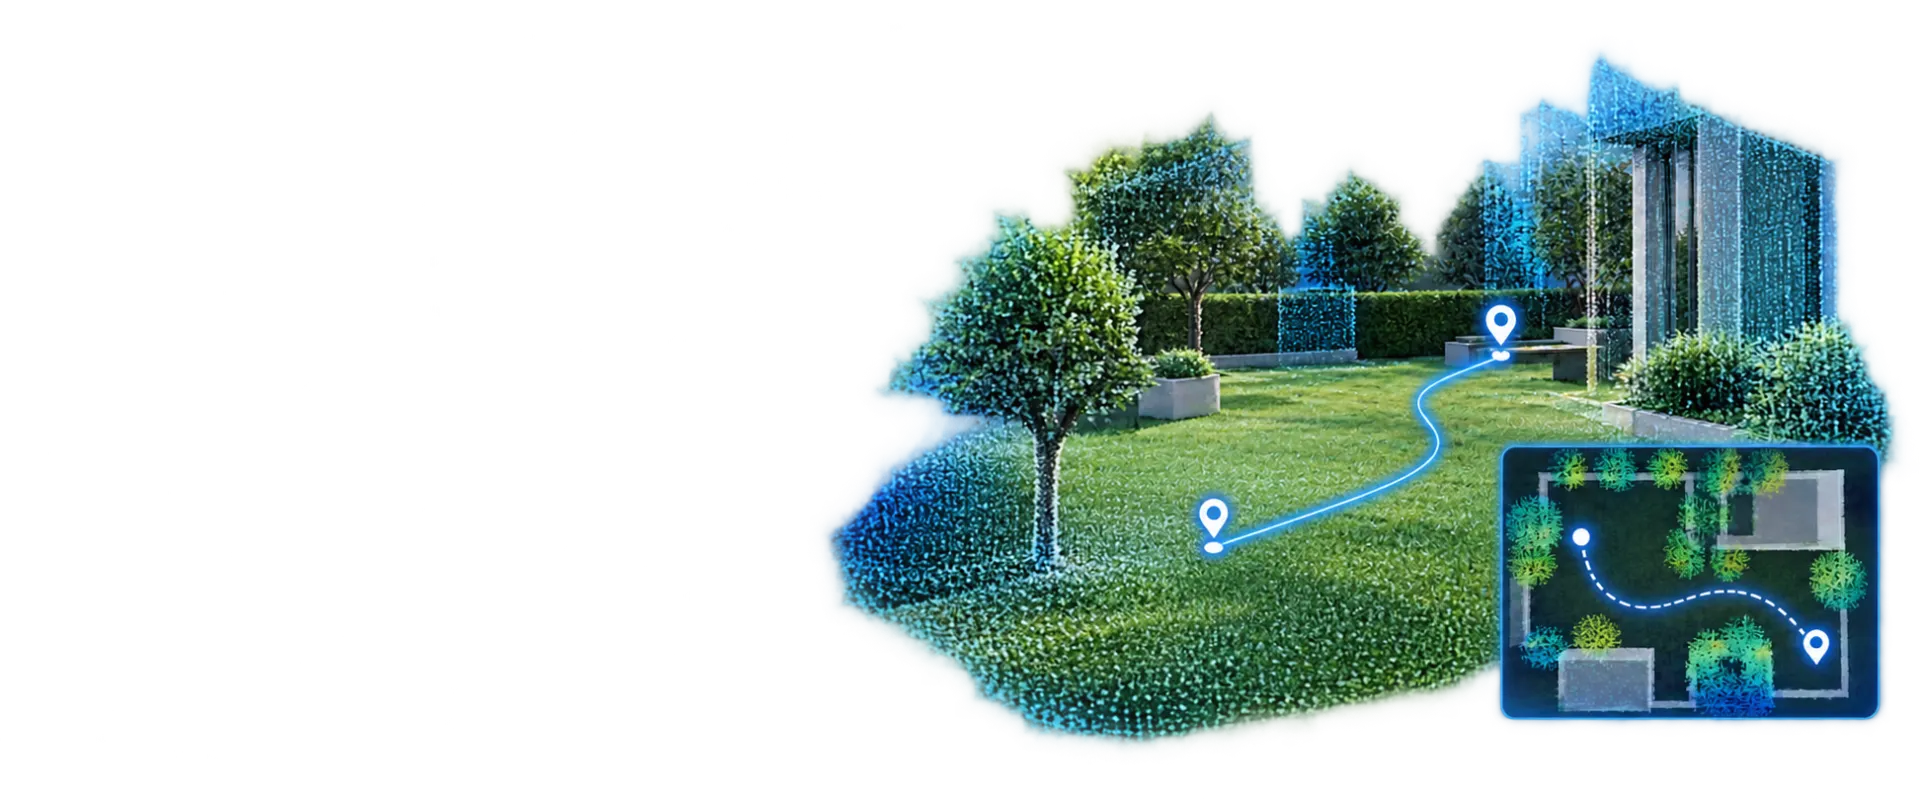
Stereo VSLAM for spatial localization
Simultaneous RGBD and left/right stereo image output supports obstacle avoidance, localization and mapping with VSLAM.
Applications
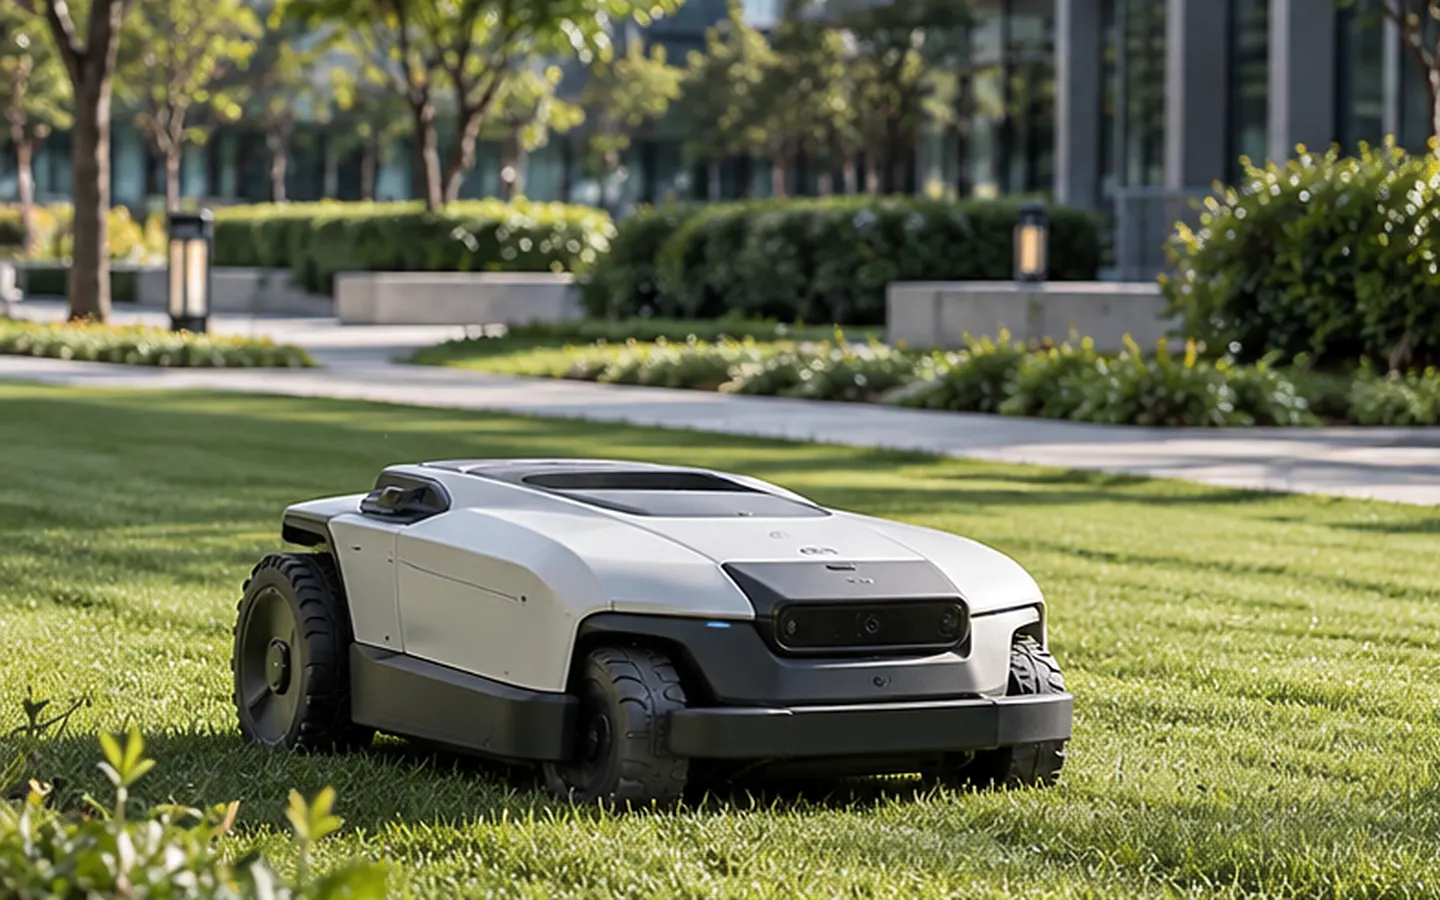
Commercial robotic mowers
Libra 2000 Series
Swipe to view all models and specifications
| Model | Libra 2000 |
|---|---|
| Product image | 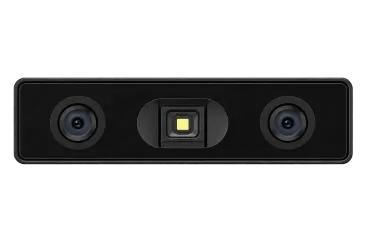 |
| Use cases | Robotic mower obstacle avoidance & SLAM |
| RGB FOV | H115° × V99° |
| RGB resolution @ frame rate | 1280 × 1080 @ 30 fps |
| Depth resolution @ frame rate | 640 × 540 @ 10 fps |
| Stereo baseline | 70 mm |
| IMU | 6-axis IMU |
| Interface | MIPI |
| Shutter | Global shutter |
| Depth performance | <1 cm @ 0.15–0.5 m; <2% @ 0.5–1 m; <3% @ 1–2 m |
| Depth processing platform | Onboard processing |