Libra1000&3000Series
AI stereo depth cameras
The Libra 1000 & 3000 series brings passive stereo 3D vision to embodied AI robots. Deep neural network stereo technology provides 3D perception from 0.1 to 10 m, improving reconstruction of low-texture, reflective and transparent objects. High-frame-rate, real-time operation on embedded platforms supports autonomous mobility and precision manipulation.
AI stereo vision for challenging objects
Deep neural networks improve 3D reconstruction of challenging objects, including low-texture, reflective and transparent surfaces.
High-quality depth. Rich spatial detail.
High-quality 3D depth data provides the spatial information robots need for obstacle avoidance, grasping and pose estimation.
High-speed data over GMSL 2.0
GMSL 2.0 high-speed output supplies visual data for SLAM, mapping and obstacle avoidance algorithms.
Applications
Libra 1000 & 3000 Series
Swipe to view all models and specifications
| Model | Libra 1000 | Libra 3000 |
|---|---|---|
| Product image | 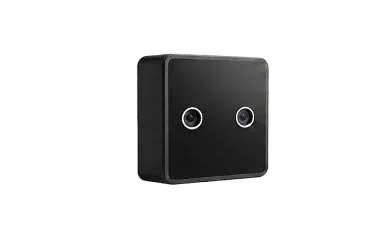 | 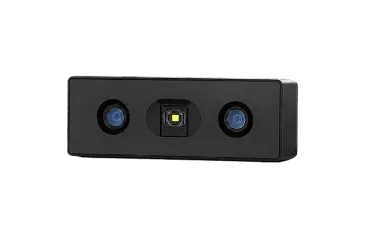 |
| Use cases | Manipulation perception | Spatial perception |
| RGB FOV | H91° × V78° | H115° × V99° |
| RGB resolution @ frame rate | 1280 × 1080 @ 30 fps | 1280 × 1080 @ 30 fps |
| Depth resolution @ frame rate | 640 × 540 @ 30 fps | 640 × 540 @ 30 fps |
| Stereo baseline | 20 mm | 65 mm |
| IMU | 6-axis IMU | 6-axis IMU |
| Interface | Fakra GMSL 2.0 | Fakra GMSL 2.0/ USB 2.0 TypeC |
| Shutter | Global shutter | Global shutter |
| Depth performance | <1 mm @ [4 cm–20 cm] <1% @ (20 cm–1 m] <1.5% @ (1 m–1.5 m] | <1% @ [10 cm–1 m]; <1.5% @ (1 m–2 m] <2% @ (2 m–5 m]; <5% @ (5 m–10 m] |
| Depth processing platform | Orin NX/AGX | Onboard processing |